Use case · LARS & heave compensation
Launch and recovery, tested before it gets wet.
A complete launch and recovery system in simulation: A-frame, winch, cable, vessel motion and active heave compensation, driven by your real PLC and operated from a tablet.
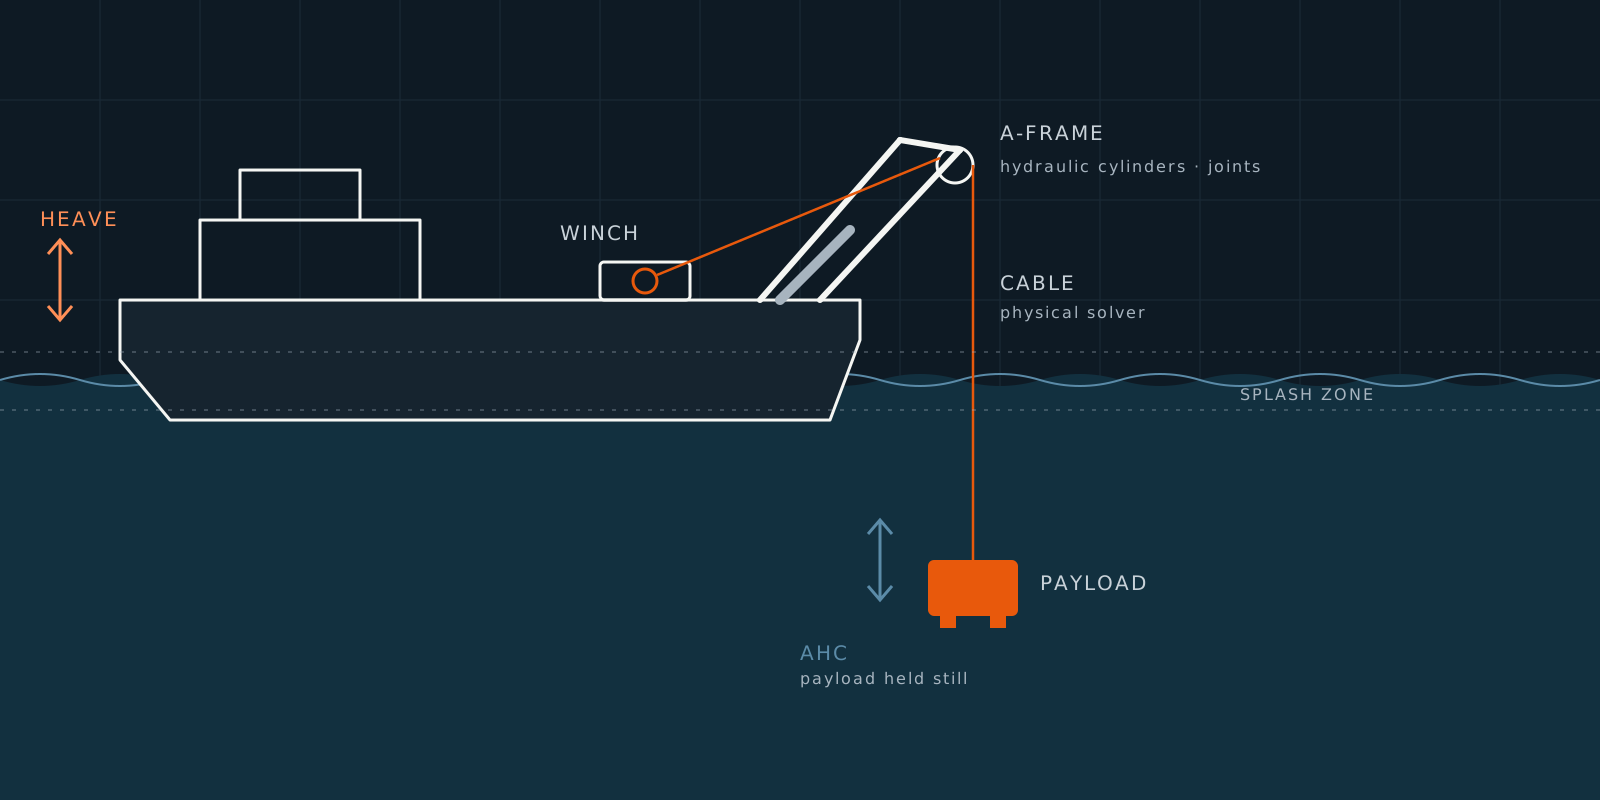
What is modelled
Every moving part, as physics.
Nothing is keyframed. Cylinders push, joints carry load, the cable stretches and the vessel moves with the sea, so what you see is what the machine would do.
- A-frame & actuatorsHydraulic cylinders as linear actuators on jointed frames, with real limits, speeds and loads.
- Winch, sheave & cableA dedicated cable solver for wire and umbilical: pay-out, haul-in, slack and snatch loads.
- Vessel motionA hydrodynamic model moves the ship with the sea state, so the deck is never still.
- Active heave compensationSimulated motion sensors feed the compensation loop, exactly where a real accelerometer would sit.
- Payload & splash zoneROVs, tooling or your own payload, through the air, the splash zone and down the water column.
Heave compensation
The ship moves. The payload does not.
Tune the compensation loop against a moving deck, watch the motion trace live, and switch it off to see what the crew would be dealing with.
Test the real control logic, not a copy of it.
Your LARS program runs on a real or virtual PLC and talks to the simulation over OPC UA. Check sequences, interlocks and failure handling before the hardware leaves the workshop.
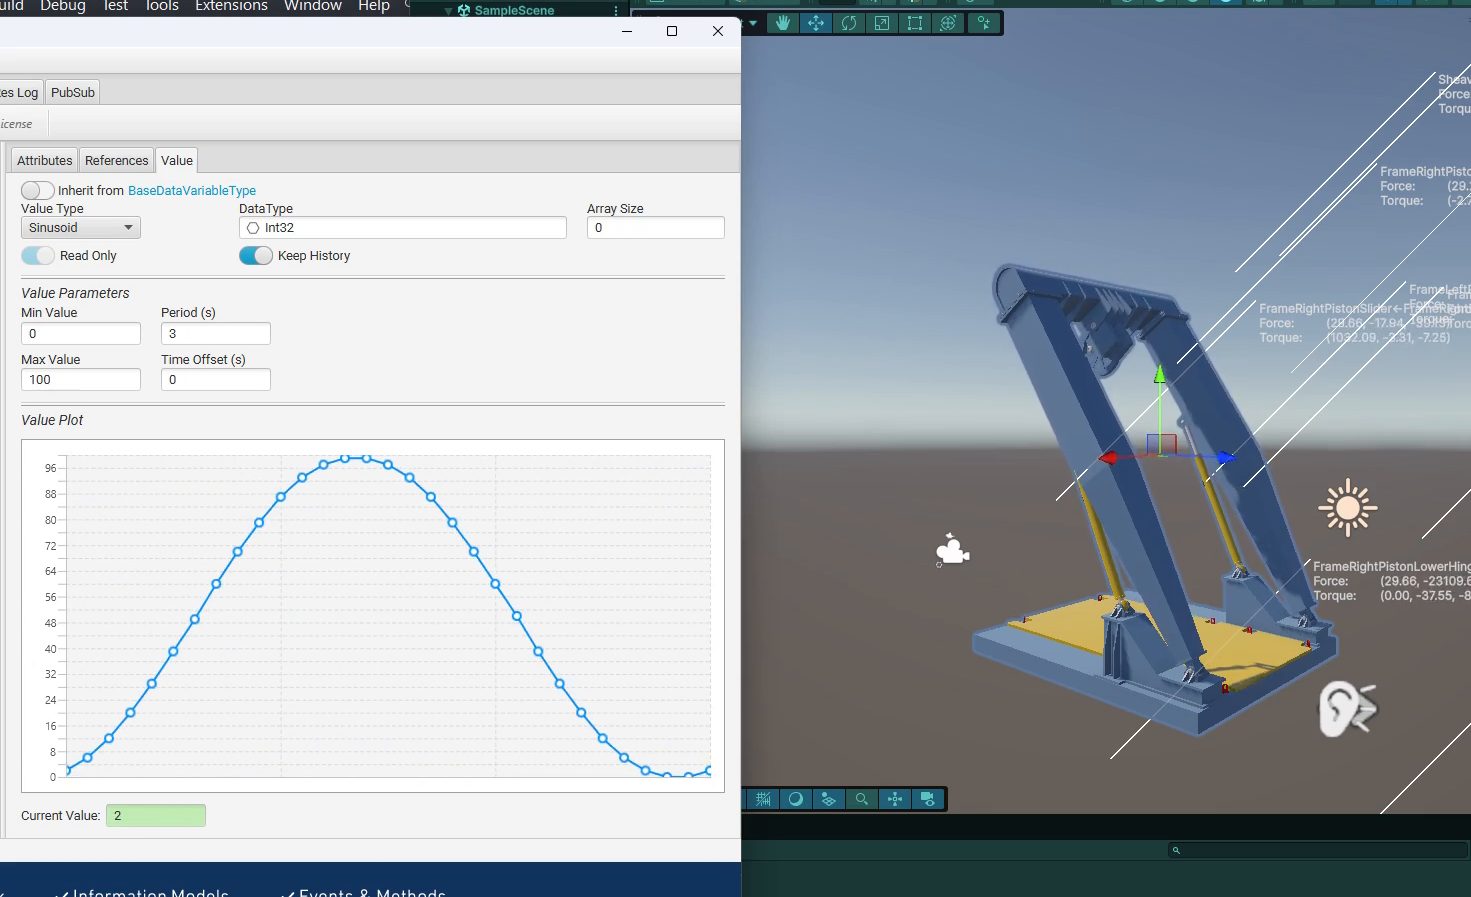
The control panel is an iPad. The view is any screen.
The operator drives the LARS from a tablet while the scene streams to a big screen, a laptop across the room or a client on another continent.
Who it is for
Equipment makers
Validate control software early, commission virtually, and show clients the system working before it is built.
Vessel operators
Train crews on the system they will use, and rehearse operations in the expected sea state and light.
Integrators
Test PLC programs and HMIs against a realistic machine instead of a bench full of switches.
Bring your LARS. We will put it on a moving deck.
Send drawings and the control spec; we will show you the system running, live, with you at the controls.